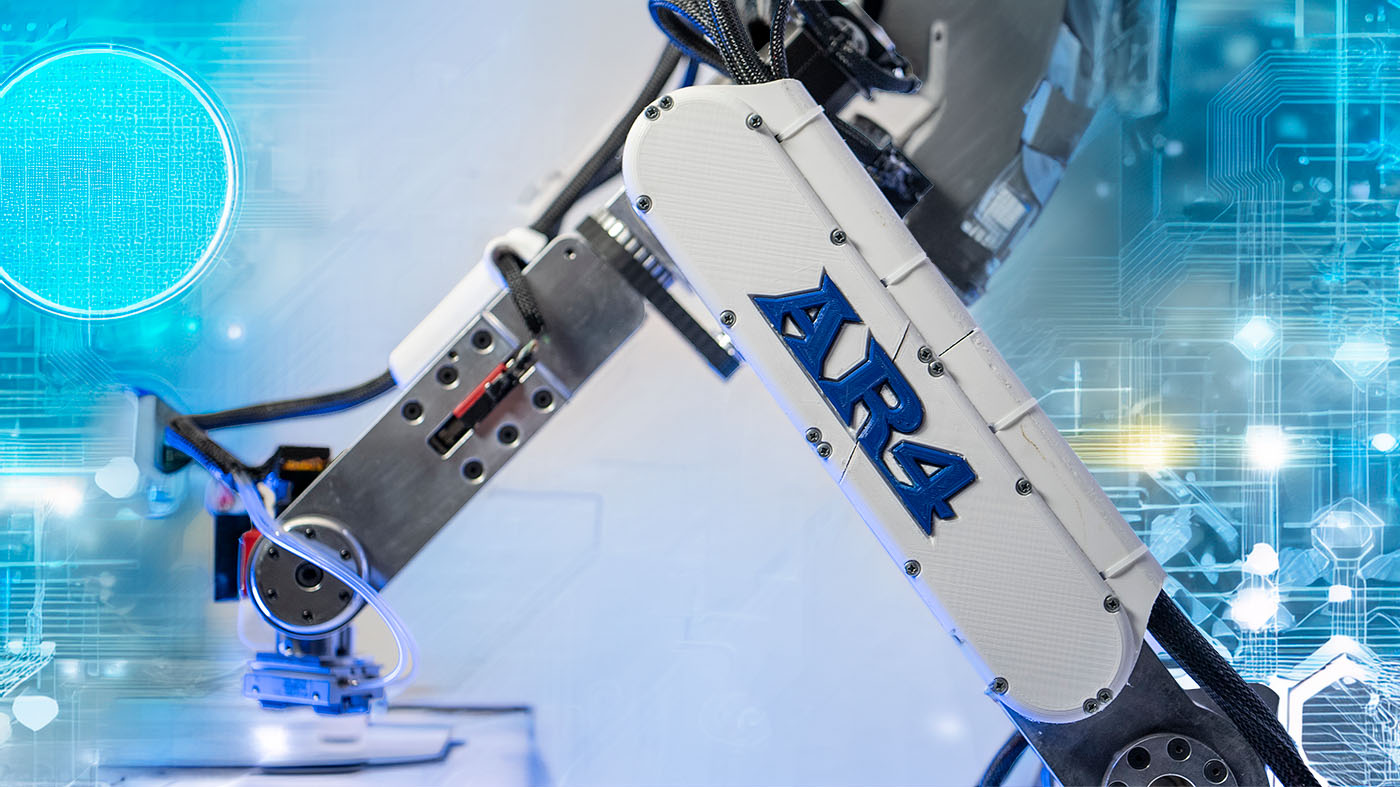
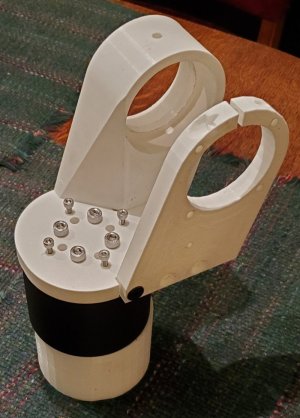
Ohhh, a robot arm. And the AR3. I too have been interested in that (now AR4) but fortunately for me the price of entry has been just a touch too high for me to jump as I really have no need. Now if I could convince work that they could use a cobot and that this would be a great intro to using them...
I bought all the parts for the AR3 but have been slow building it. Meanwhile he came out with the AR4 with different encoders etc. It's backwards compatible so not a big deal but with $400 or so invested in everything I don't really want to redo it as an AR4.
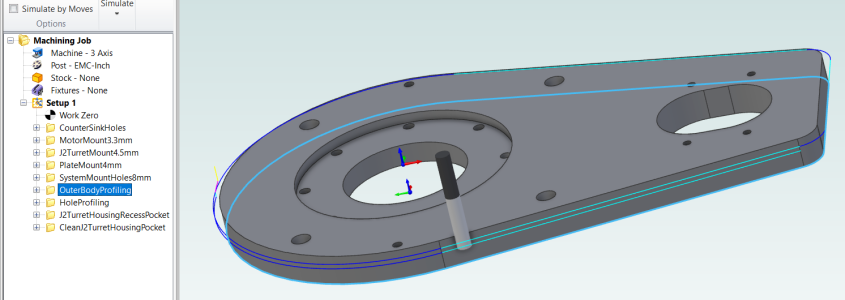
I wanted to make it a tool changer and part swapper for automating mill operations. And because I think a robot arm is just plain cool!
It was 2.5 years ago that I did all the drawings from his or from the STL files that a friend JoeMac turned into STEP files. All the parts came in. Even made some patterns for the castings to keep the cost of metal down. Then the family disaster so no interest in doing anything for 2 years.
Anyway. Ran into another problem... Never ends... Although I should expect 42 problems I guess.
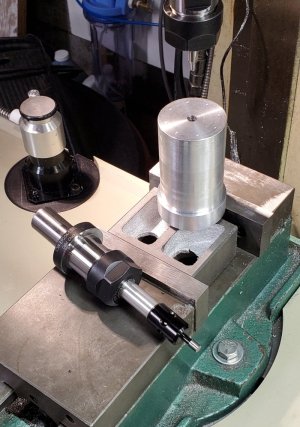
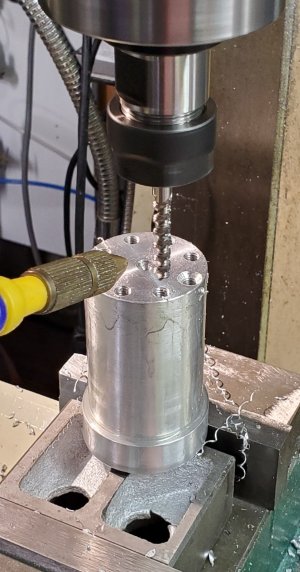
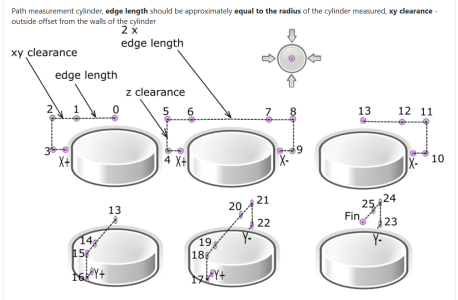
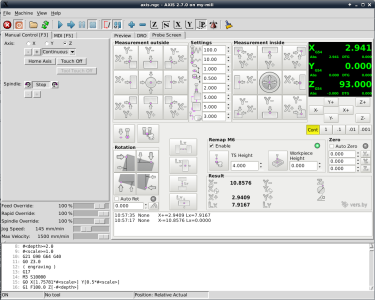
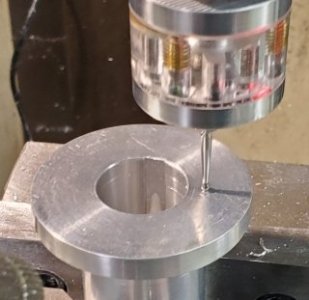
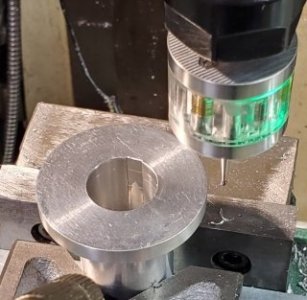
Used my touch probe with LinuxCNC to find the center of the Joint 1 spindle so I could drill the 8 hole pattern. Probe goes over to the left and finds the edge. The distance it moves from centre is supposed to be just over the radius of the part so I set it at 1".
All went well. Moves over, goes down, comes back, touches, moves off and comes in slowly for second touch. Then lifts up and it's supposed to move 2x that radius value (2") plus Clearance x 2 (0.2" x 2= 0.4") to the other side of the round piece. Doesn't go 2x. Goes half the distance. Something is hooped in the G-Code. Don't want to try and fix it at the moment.
Instead I pulled out the LED based touch probe and used my Shumatech DRO-350 to find the centre and then store the locations for 8 holes. Worked through that manually and now have 8 dimples in a circle that look right.
Glad I kept the manual feature and DRO.