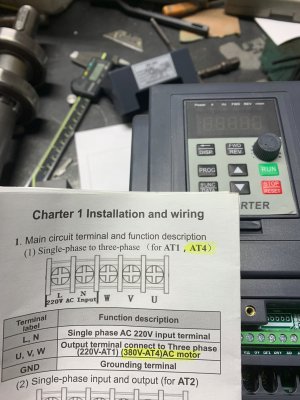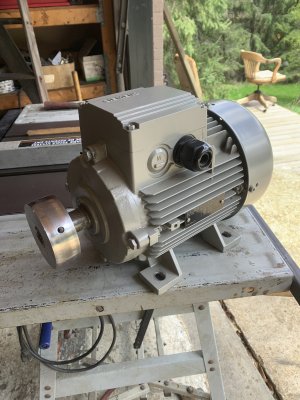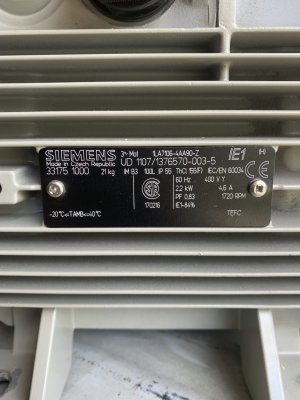

If I try to start the mill with the pot above 10% it just shuts down and I have to turn off the power, let it reset and turn the pot down.
To me that sounded like the torque compensation you were talking about.
To me, it sounds like SLV mode that isn't setup correctly. If so, when you get this working you are gunna be a very happy camper!
Most guys just want variable speed. That's only because they didn't know how much better SLV mode is.
@TorontoBuilder explains it at the functional level. I like to explain it at a higher level that's easier for us mere mortals to understand.
A motor with a position sensor can be better controlled because a computer can know exactly where a motor actually is vs where it should be. Put a bit differently, if a motor isn't where the computer thinks it should be, a computer that understands the motors operating requirements can send it the exact voltage and current corrections necessary to get it to where it should be optimally. In essence, SLV is a mode that the computer uses to know the position of the motor rotor without needing a sensor. It uses the motors own back emf and feedback from the motors power absorption to know its position. Knowing its position and operating parameters allows it to optimize the phase and power applied to the motor as a perfect match within the basic driving frequency. Basically changing the driving power to match what the motor needs at each tiny fraction of rotation. At the level of a human operator, thus translates to a motor that is happy happy happy. It's quieter, smoother, and more responsive than it could ever be otherwise.
A normal VFD outputs a variable frequency 3-phase sinusoidal voltage chopped at the operating carrier frequency. A VFD operating is SLV mode outputs a more precise non-sinusoidal waveform that much more closely matches (leads and lags) what the motor needs at the sub waveform level.
I am fairly certain that the best VFDs do this better than the lesser ones do. But anything is better than nothing. SLV mode is quite literally a paradigm step forward in motor control.